Project overview
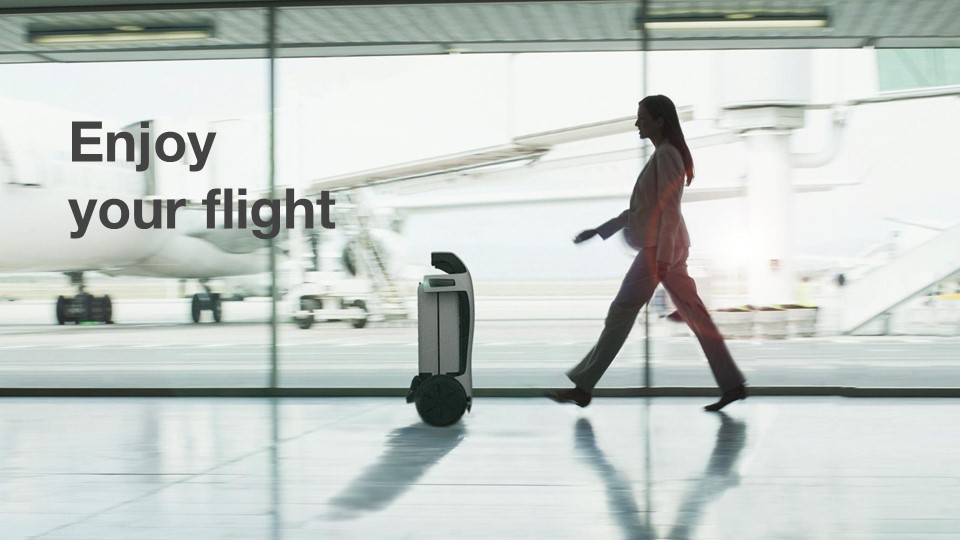
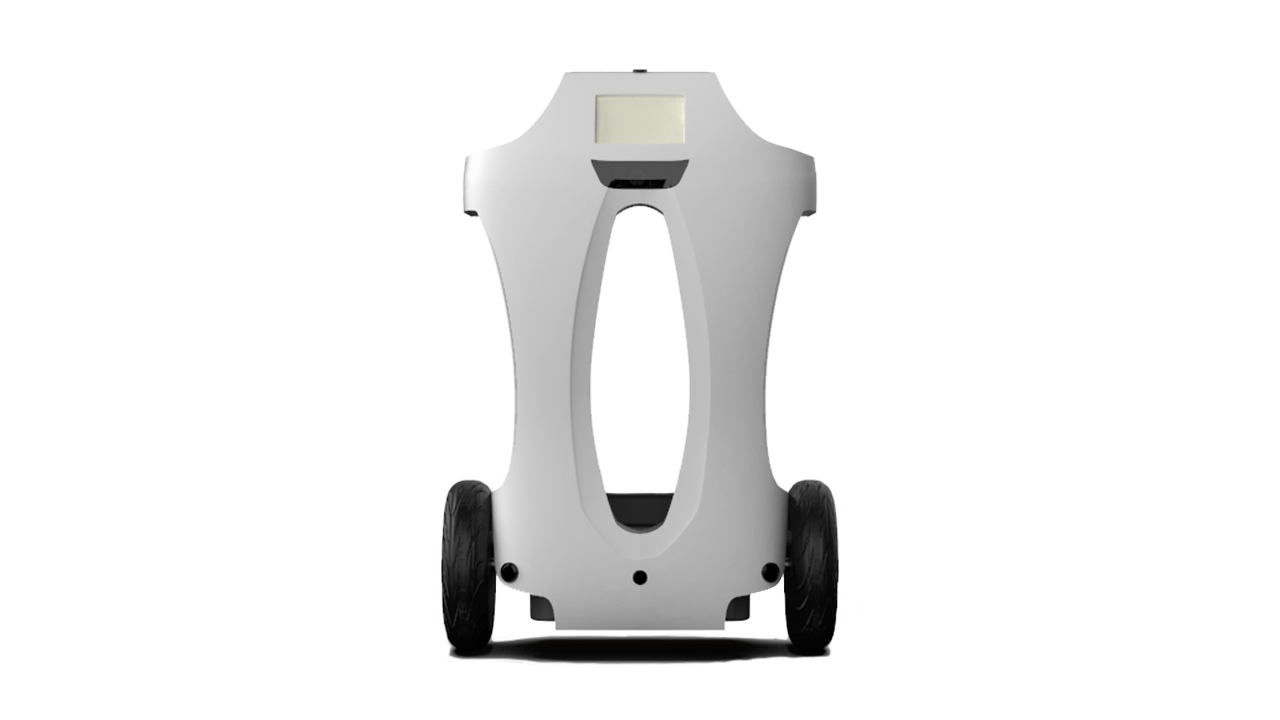
ATA is a compact autonomous robot designed to escort travelers through terminals, secure their luggage, and sync with flight information. It blends robotics, IoT, and service design to smooth the entire airport journey.
- Supports luggage transport, navigation, and flight updates.
- Connects to terminal services via mobile or web apps.
- Designed for safe navigation in dense passenger flows.
Problem setting
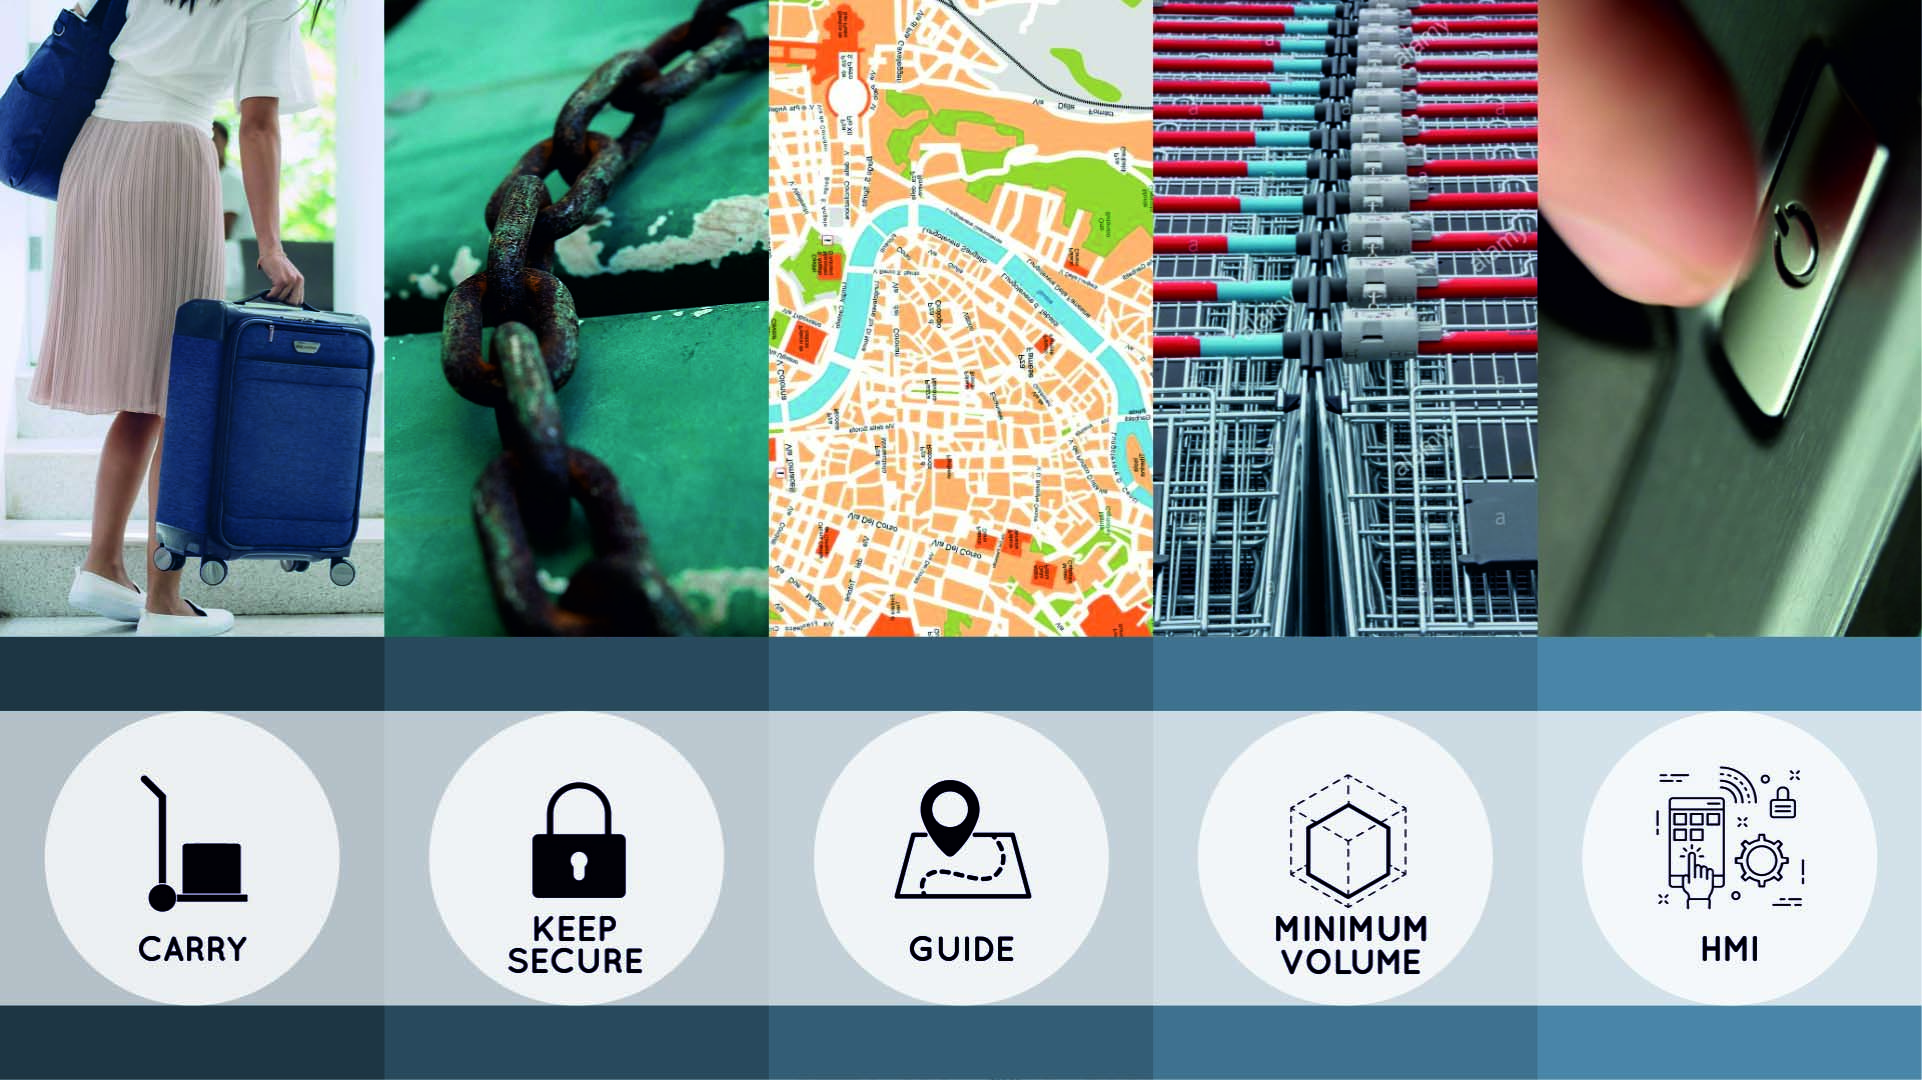
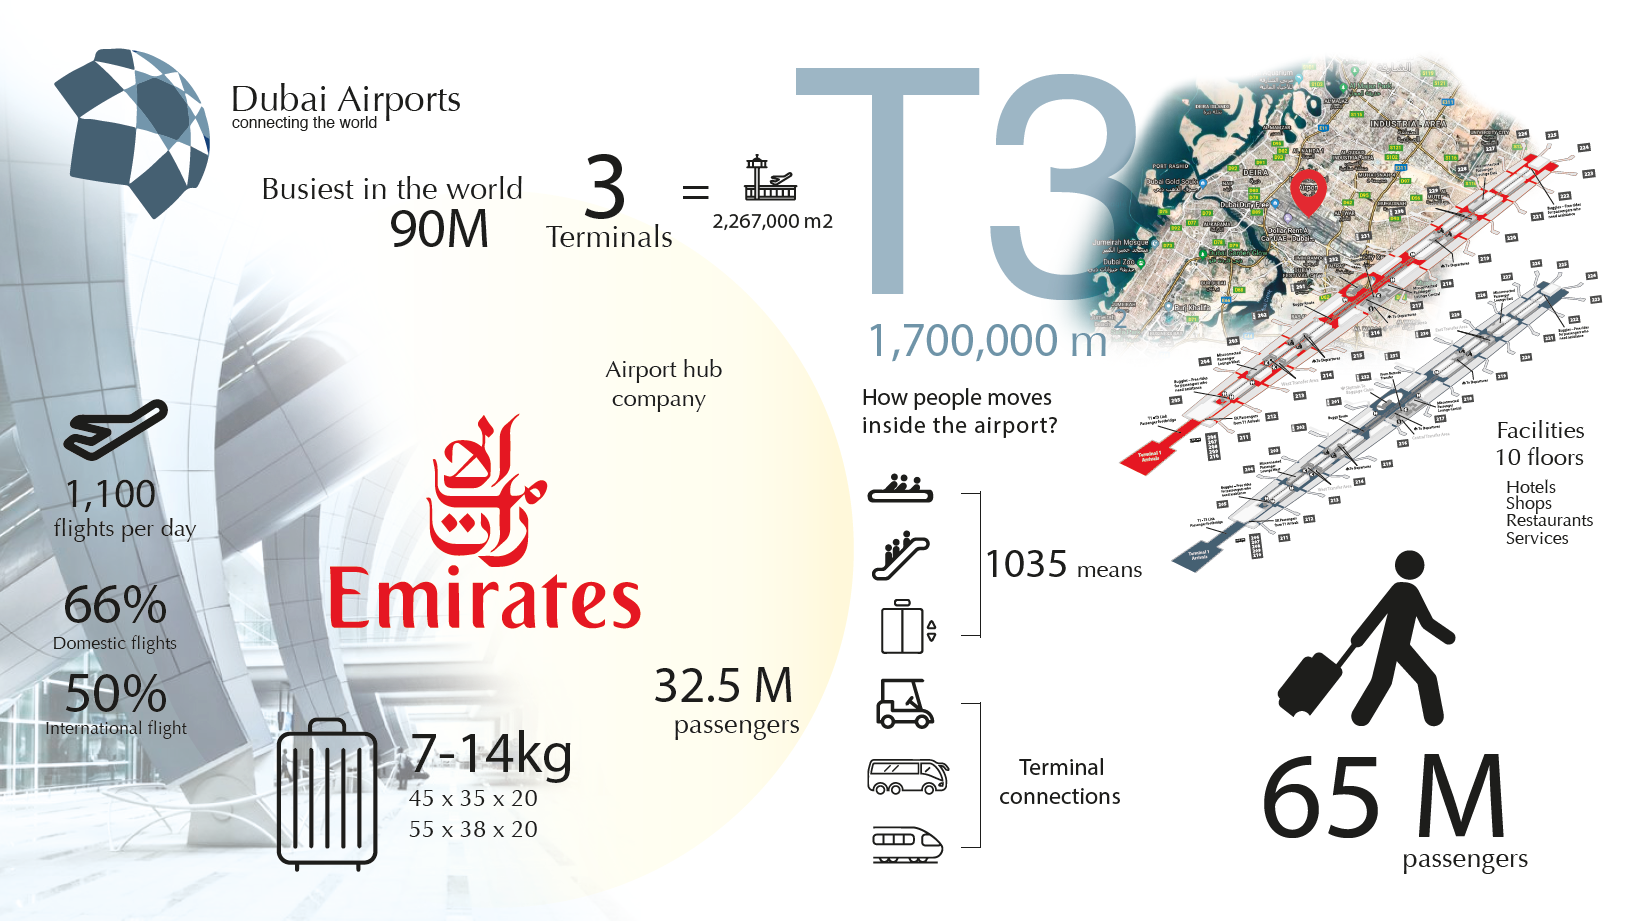
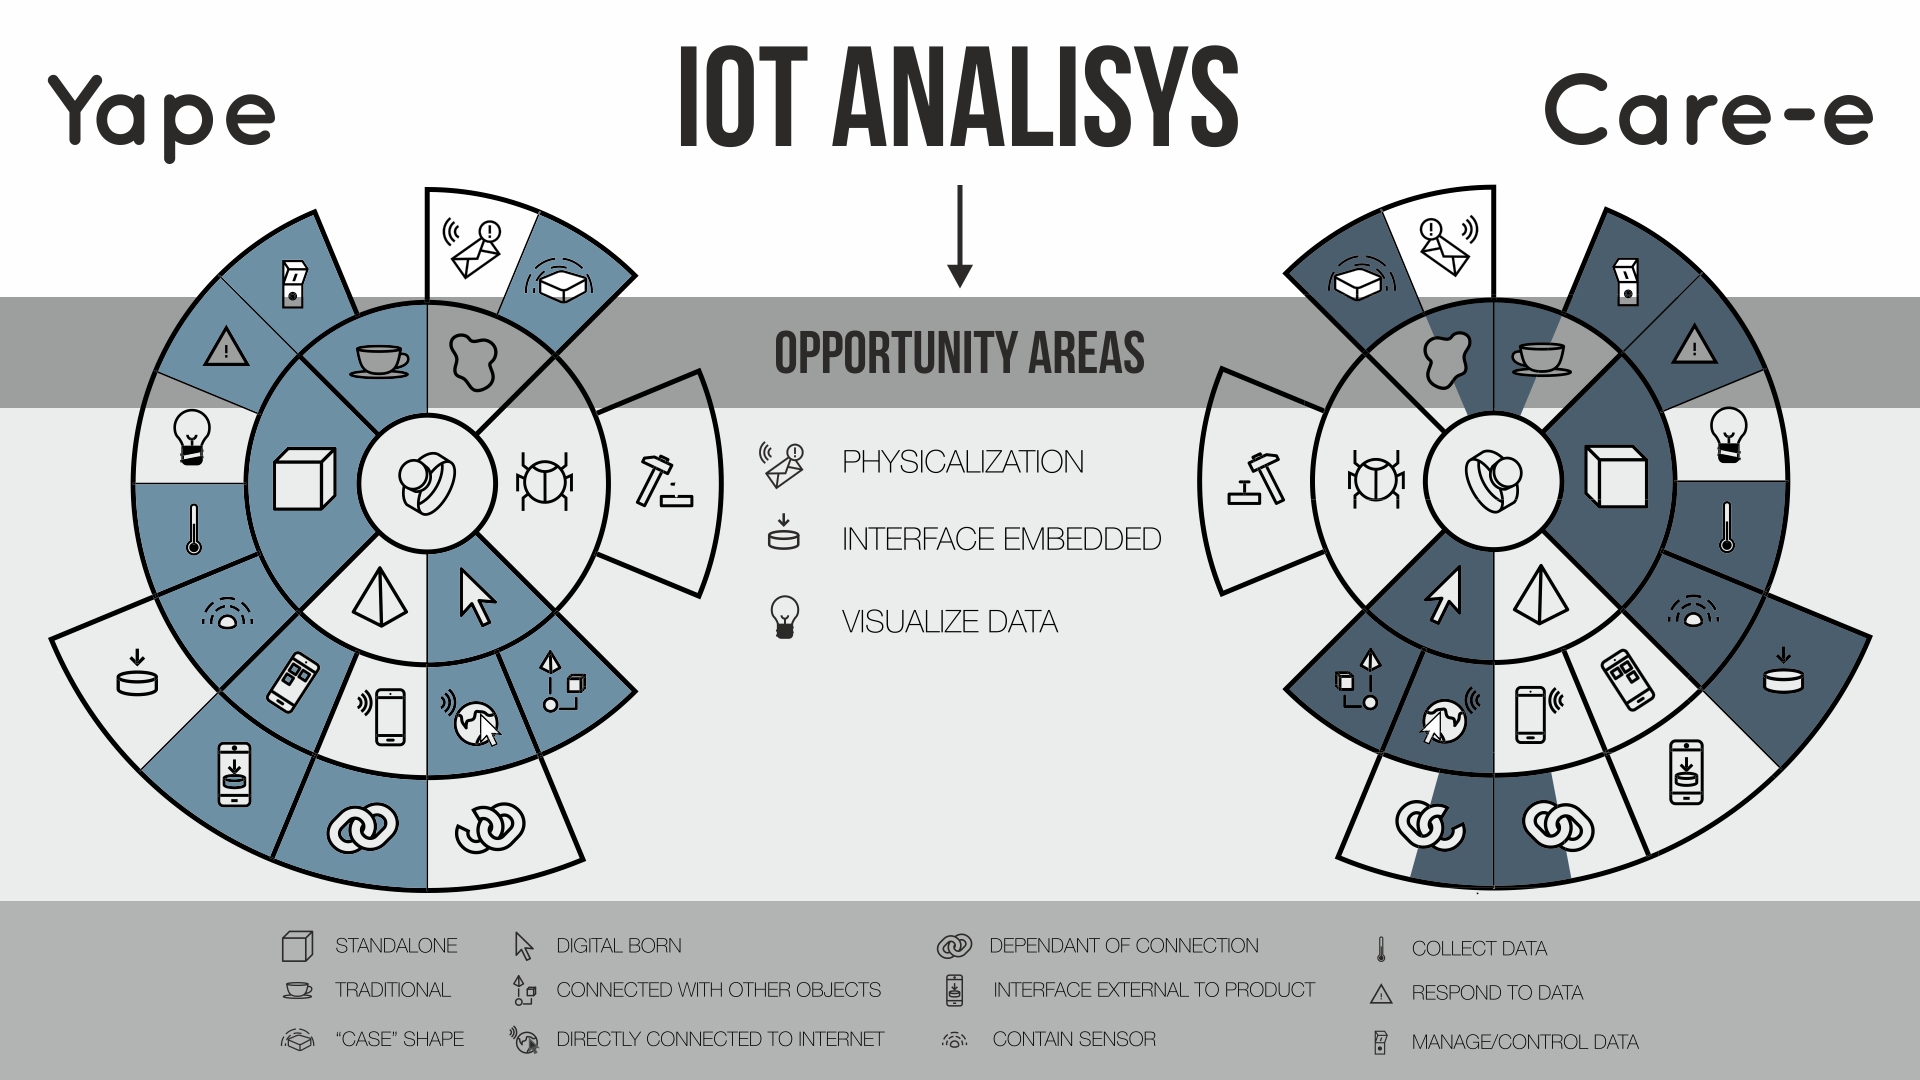
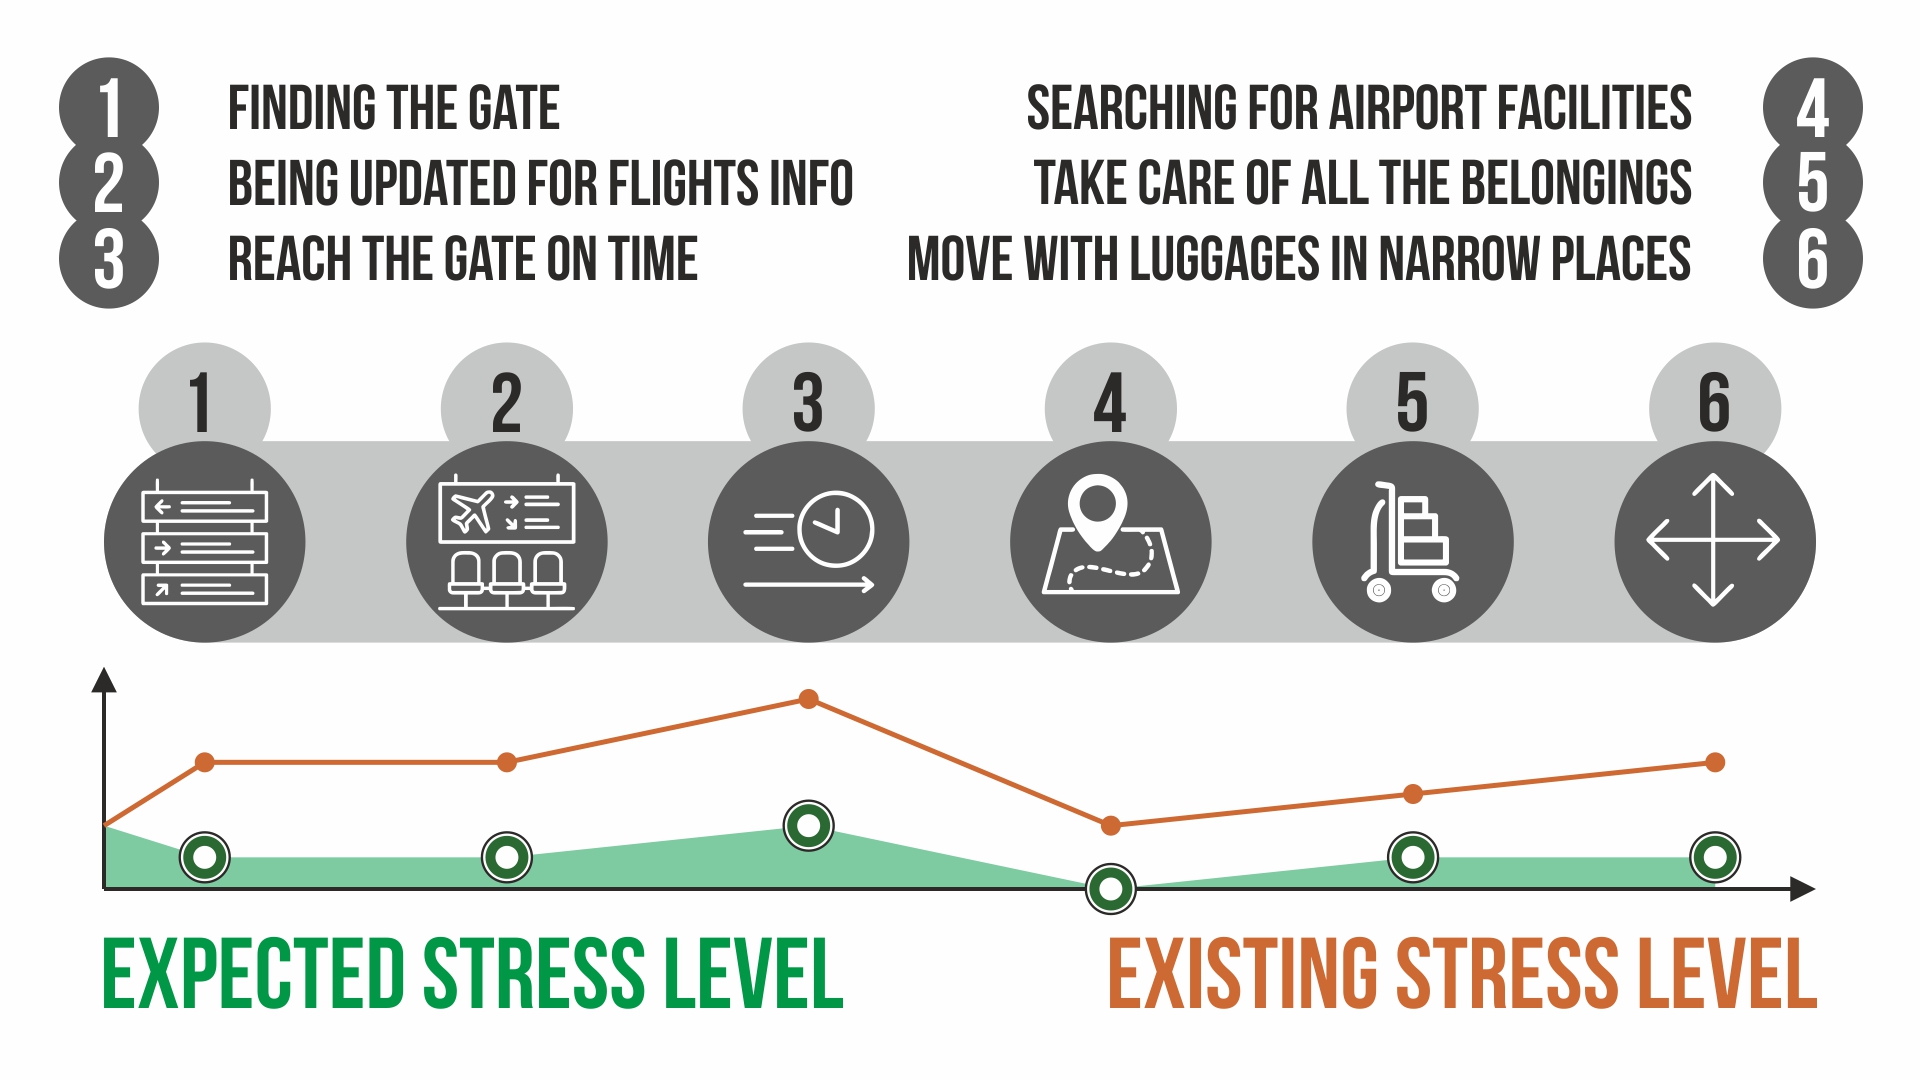
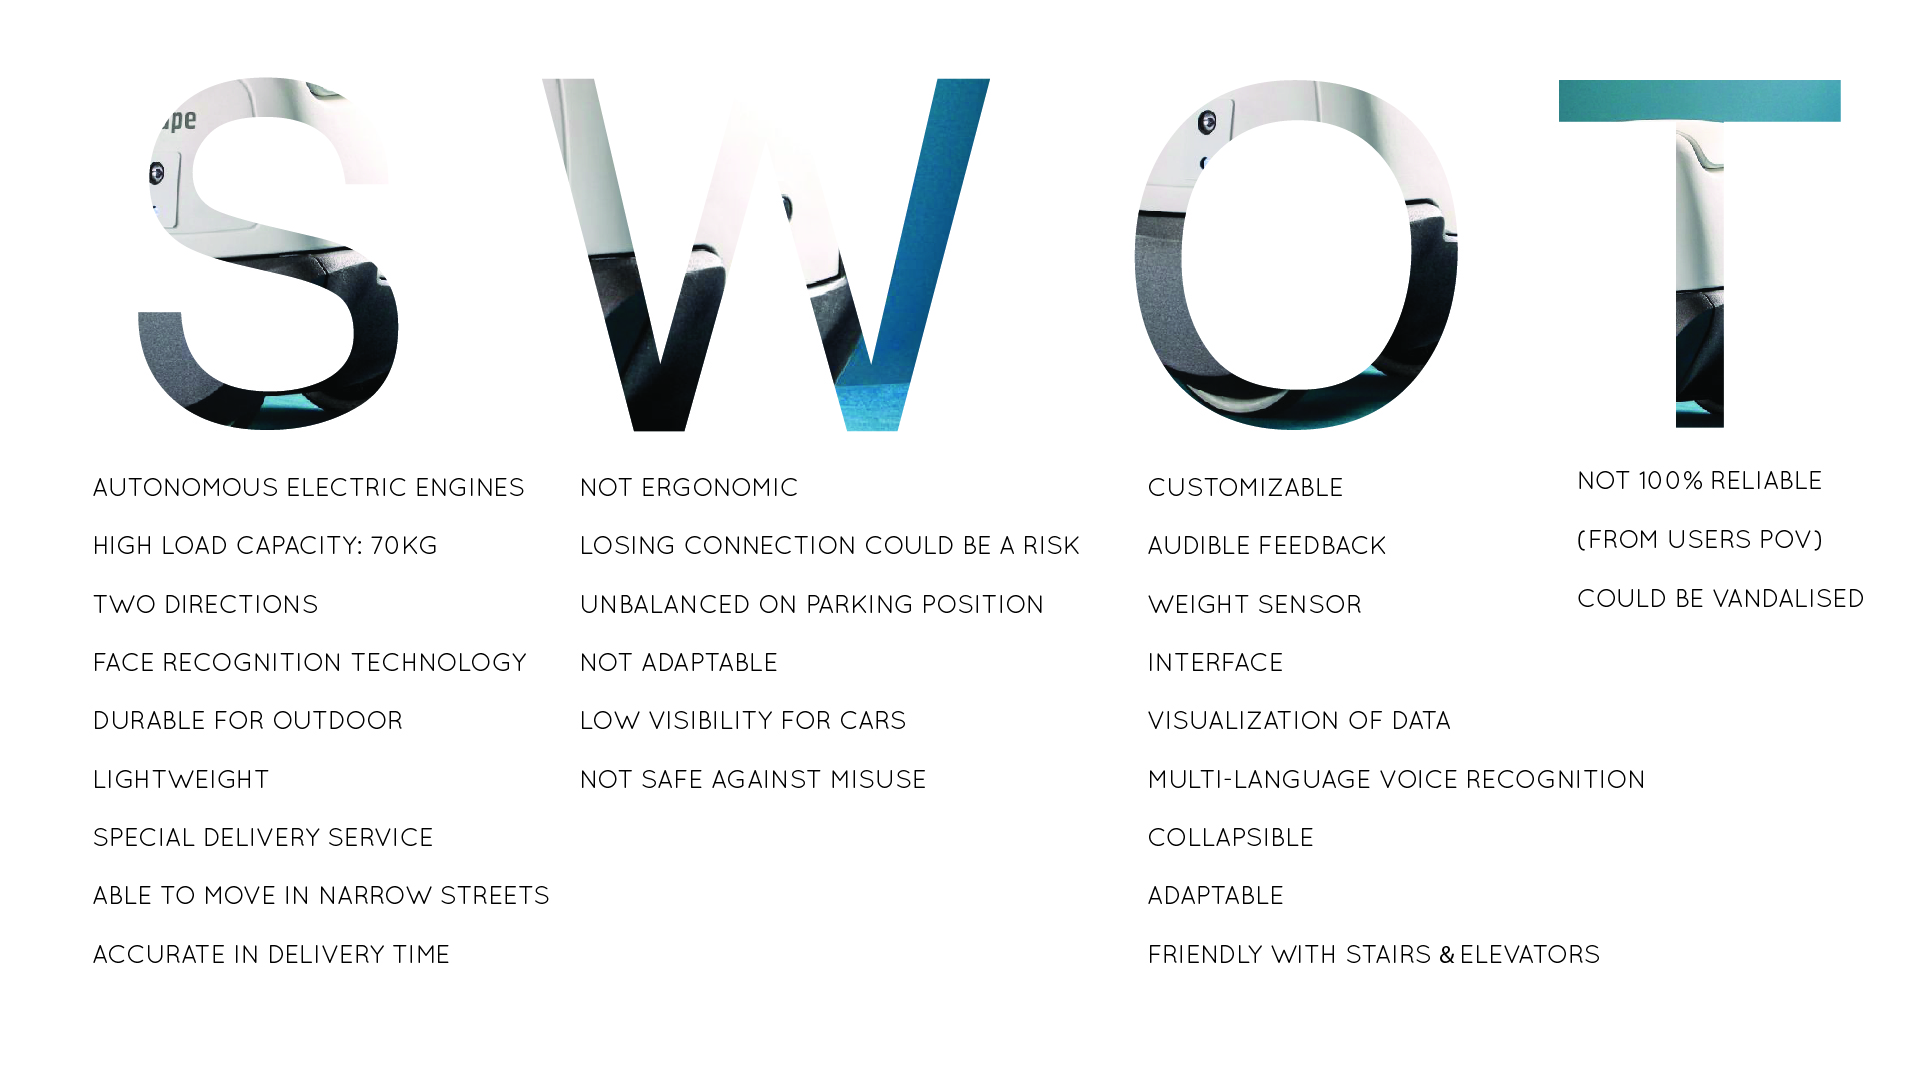
We benchmarked autonomous airport services and mapped traveler frustrations to define the most critical moments where help is needed: navigation, baggage safety, and time awareness.
Brief distilled
Reimagine YAPE as an autonomous travel assistant: keep luggage safe, provide guidance, and deliver information with an intuitive interface inside busy terminals.
Luggage arrangement
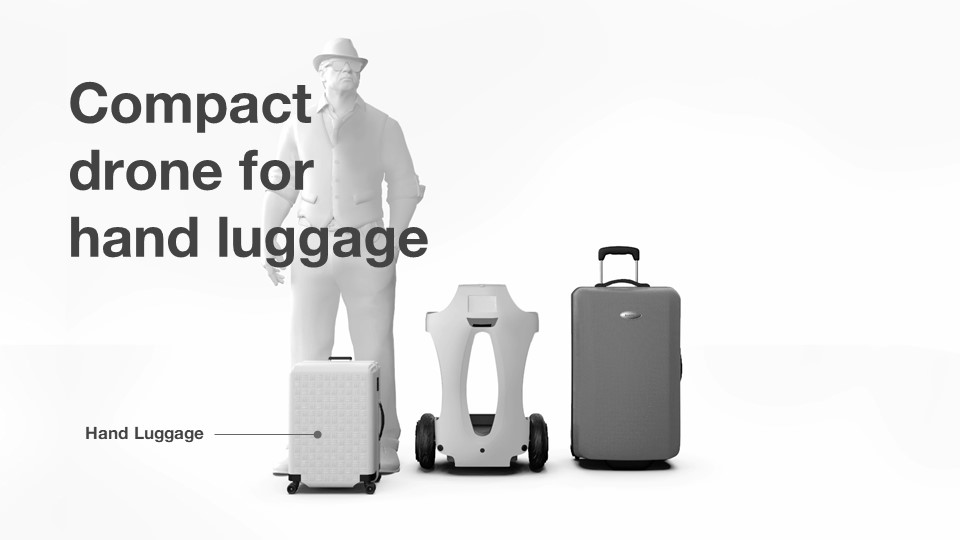
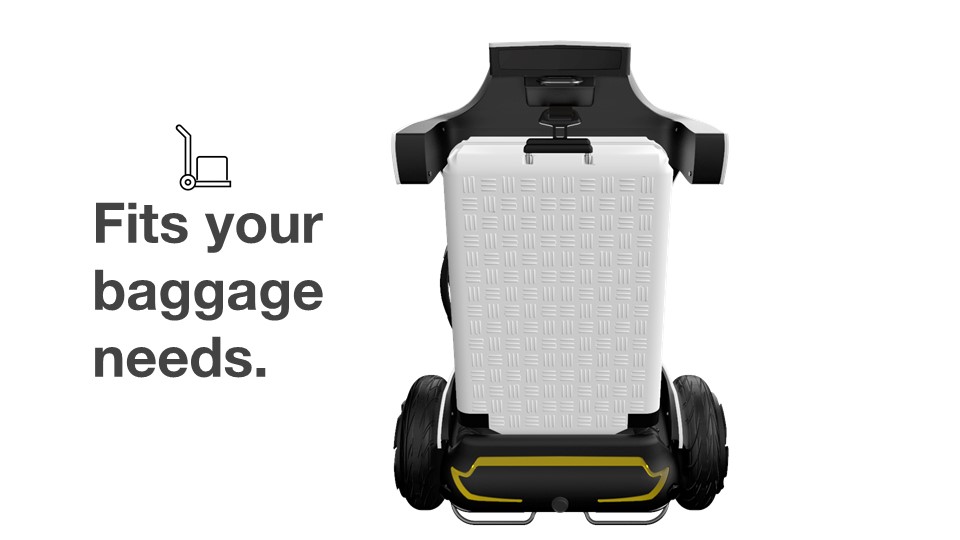
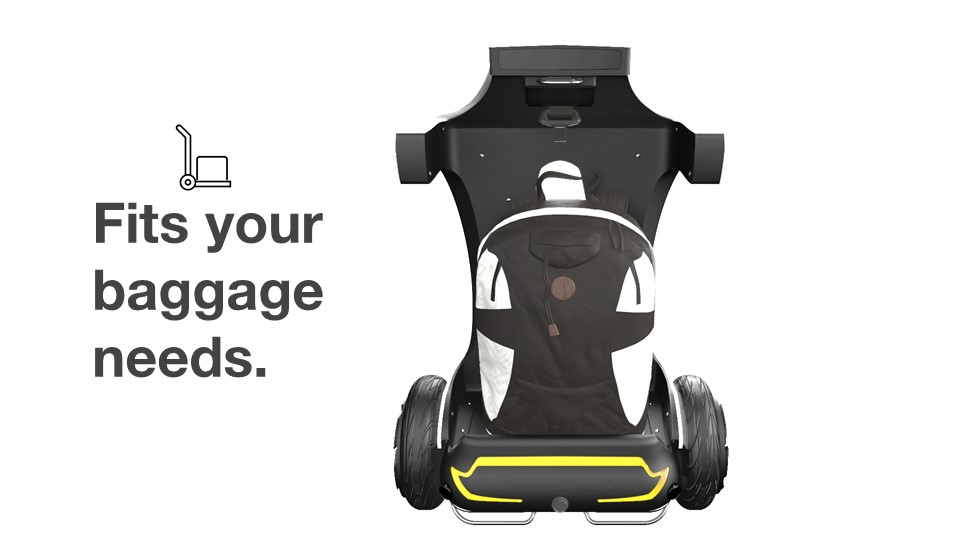
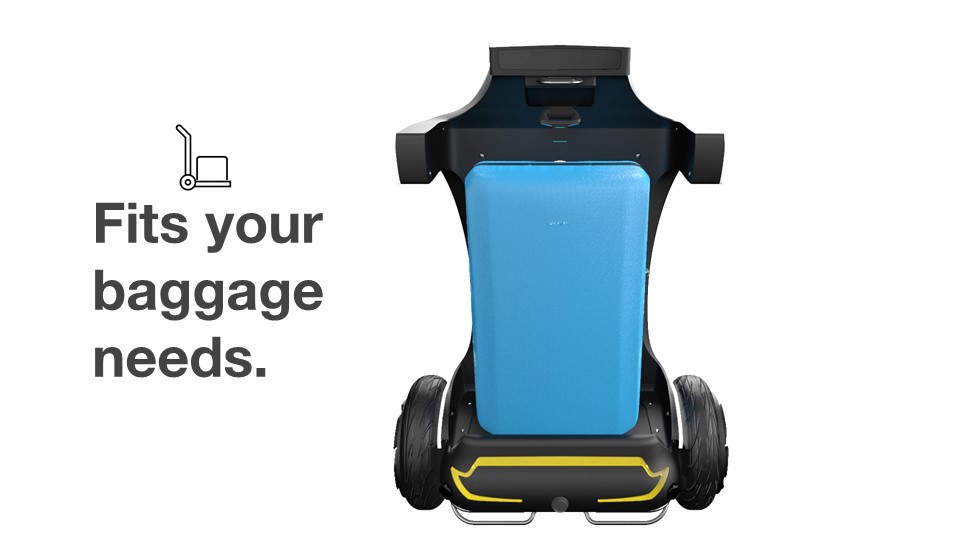
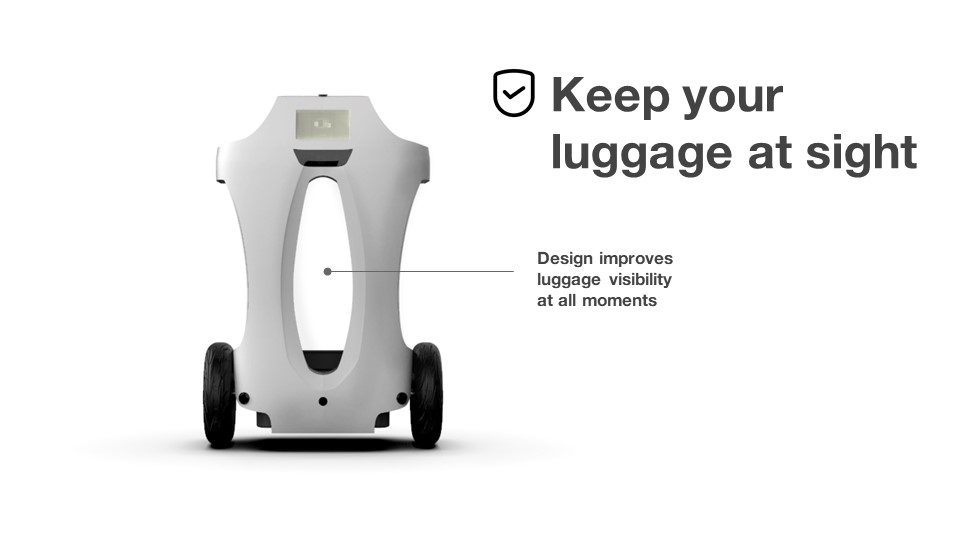
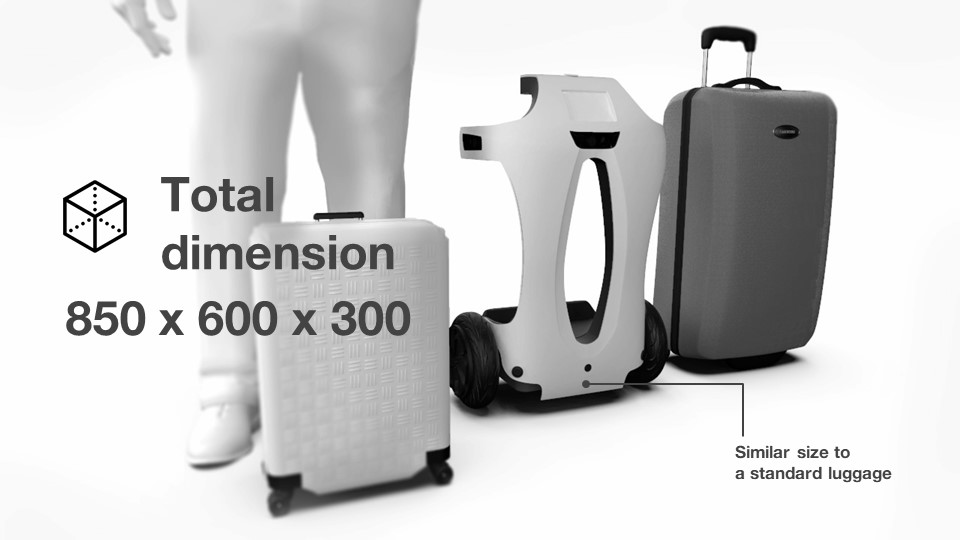
ATA accommodates varied carry-on sizes while keeping belongings visible and secure. A dedicated visualization spot keeps passengers aware of their items at all times.
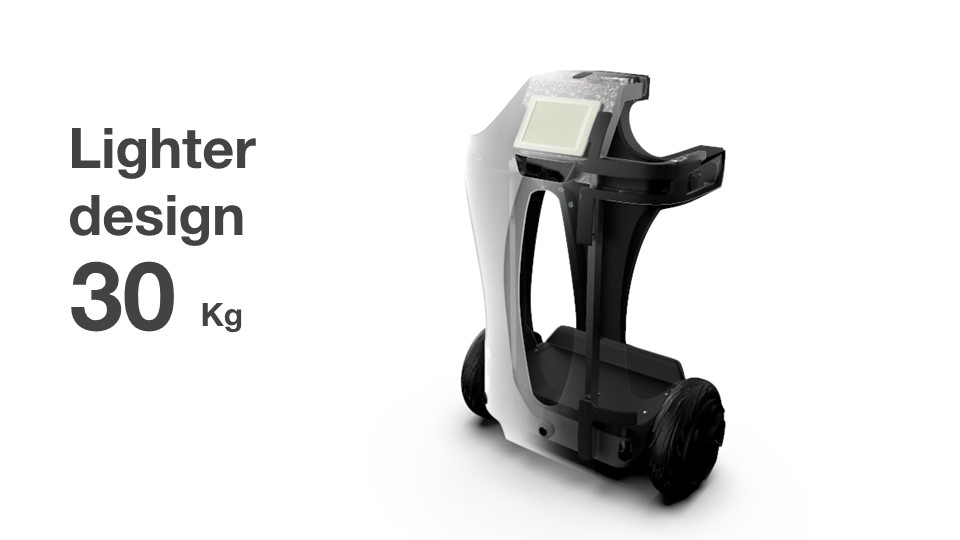
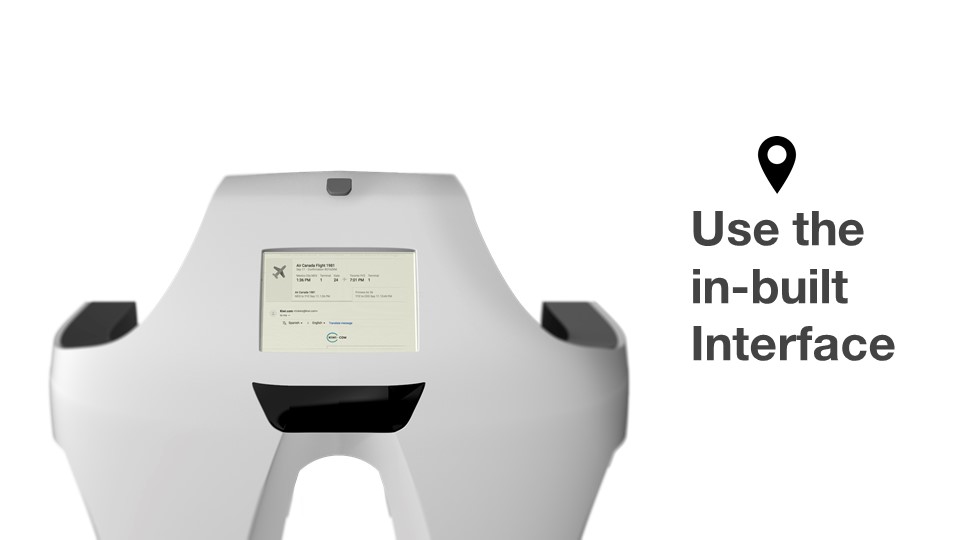
Dimensions & main features
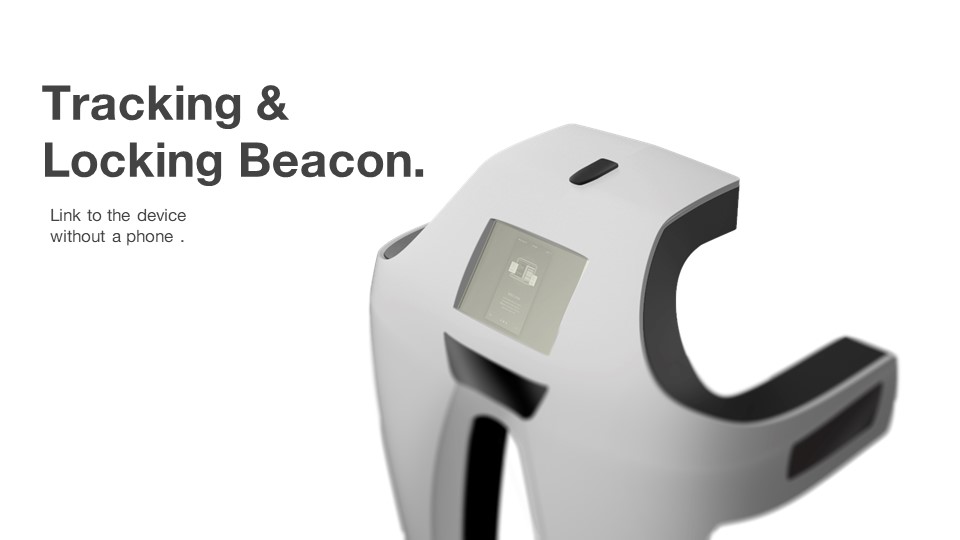
We defined a set of critical features derived from research, including secure storage, connectivity, and a clear safety language through light cues.
Connectivity & safety
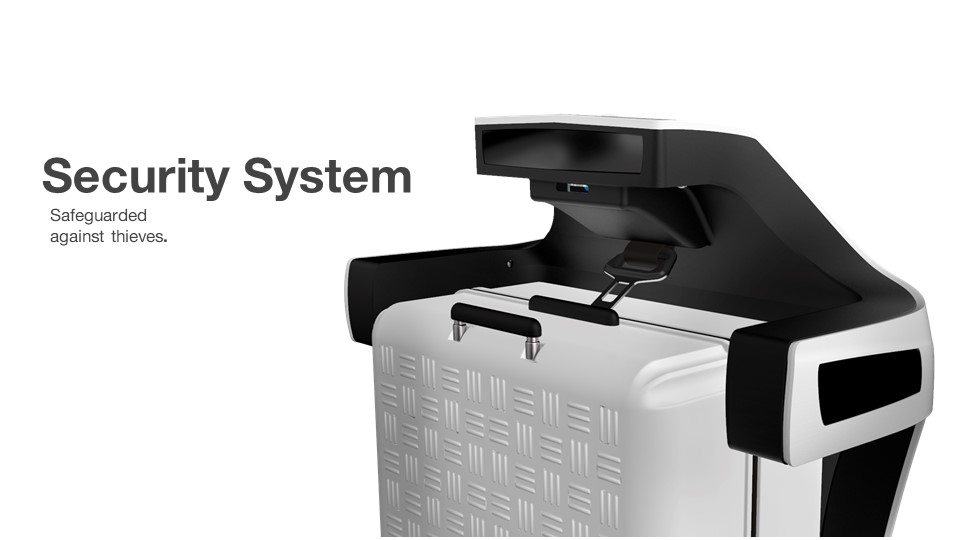
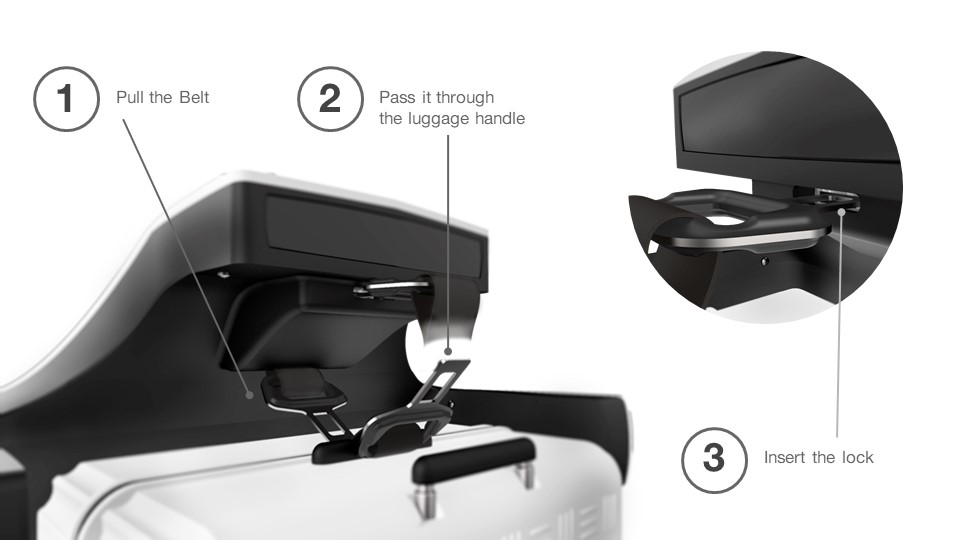
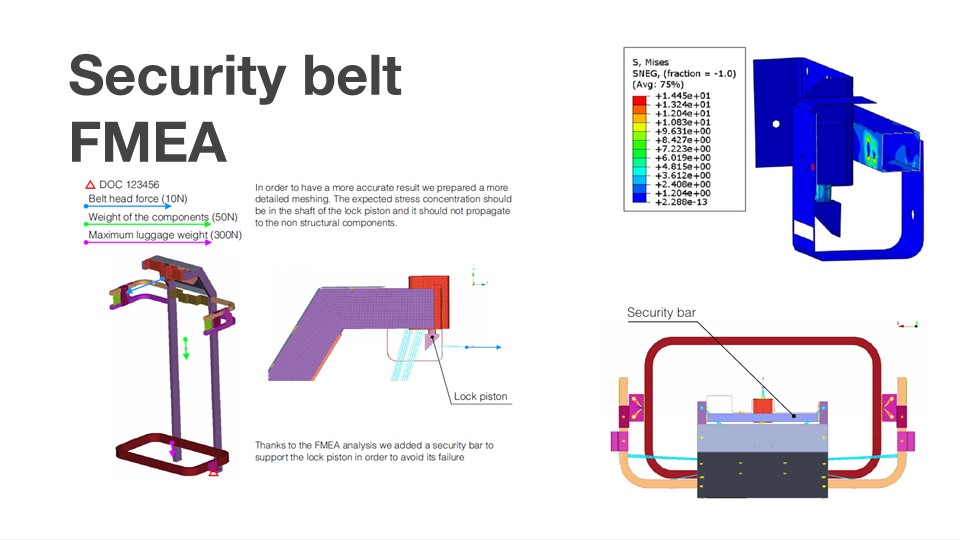
ATA integrates a beacon-linked safety belt and visual status indicators to secure luggage. Connectivity enables live flight updates and remote control through a web app.
Safety lighting system
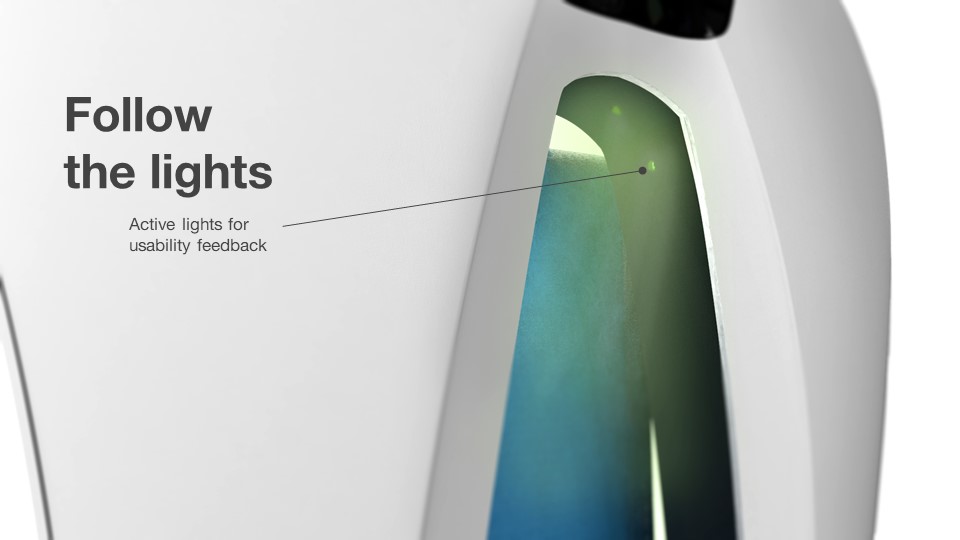
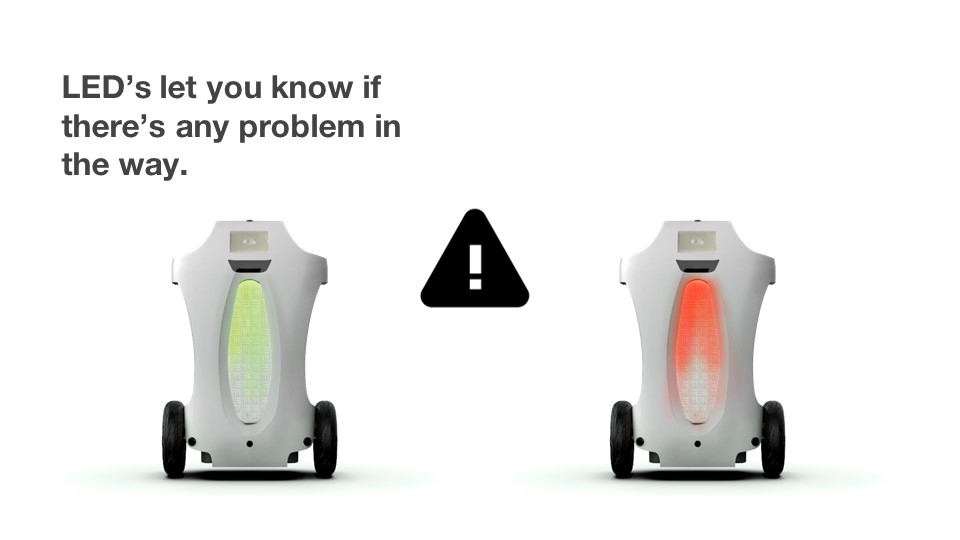
Light cues signal obstacles, changes in itinerary, and system status while reinforcing the security perception for travelers.
Stability system
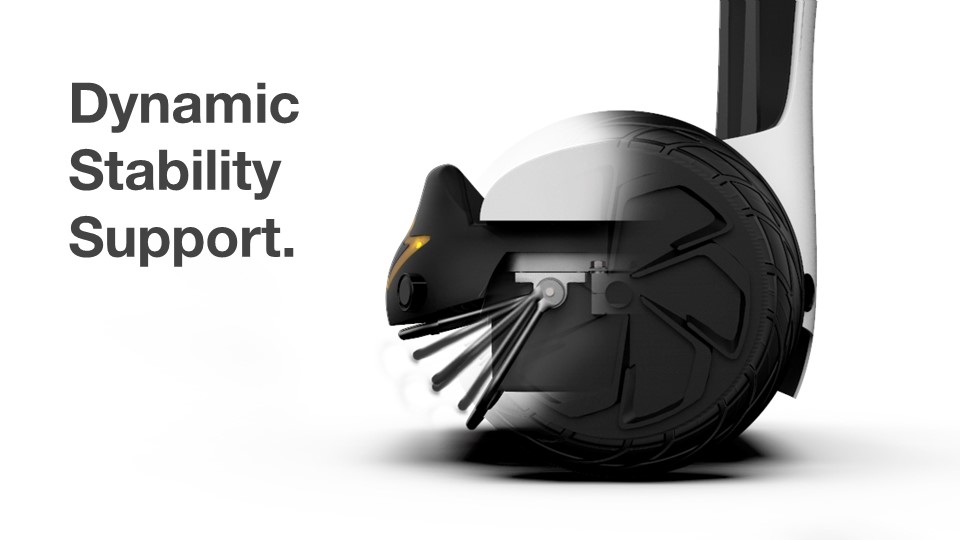
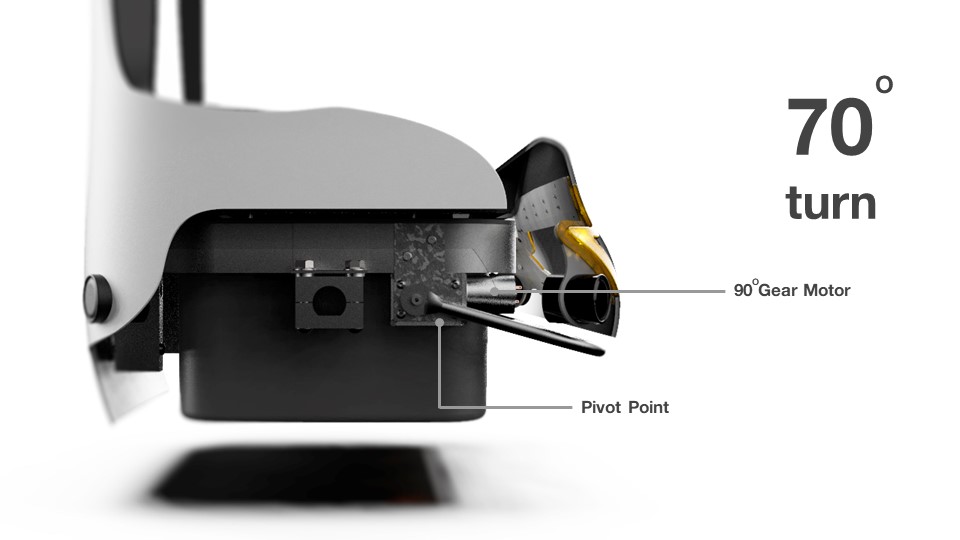
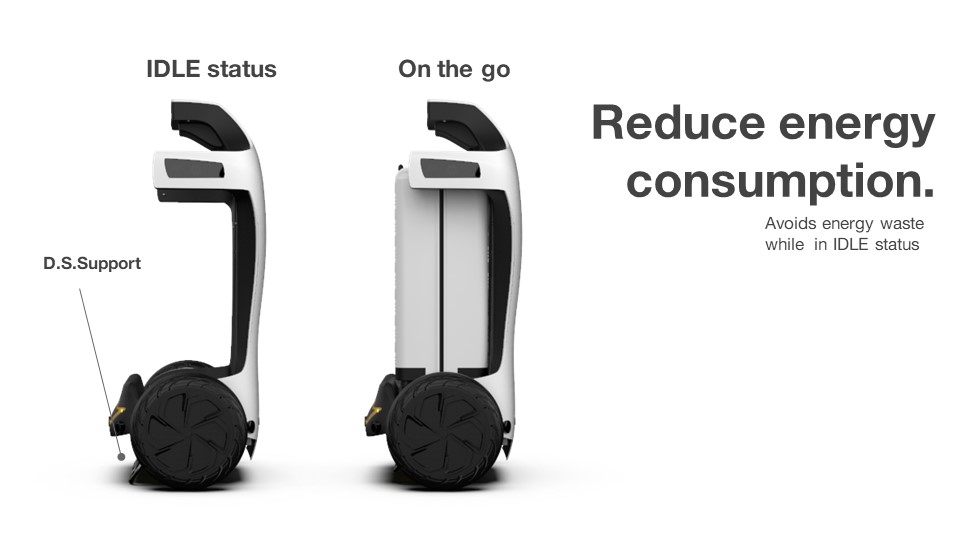
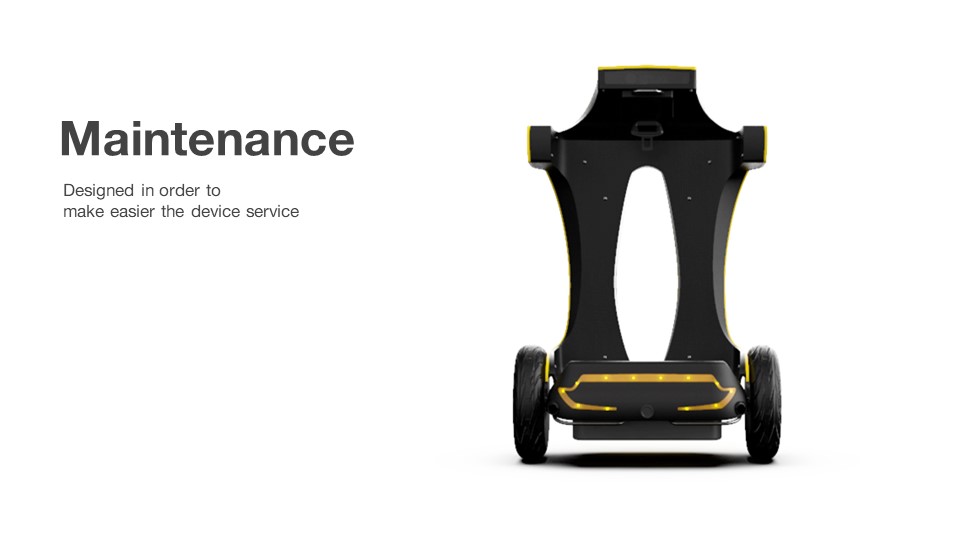
To reduce energy consumption while idle, we introduced a stability bar that supports the inverted pendulum structure and keeps ATA upright in standby.
User experience flow
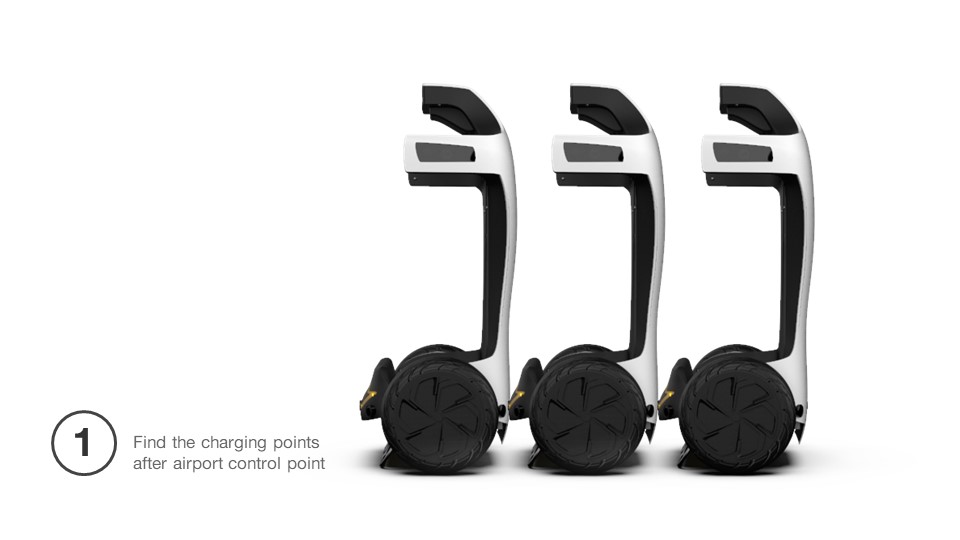
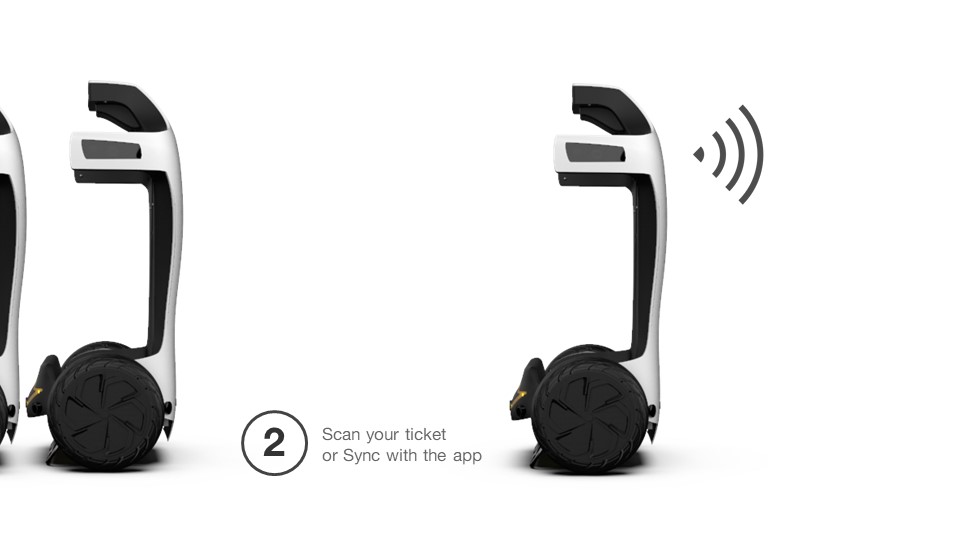
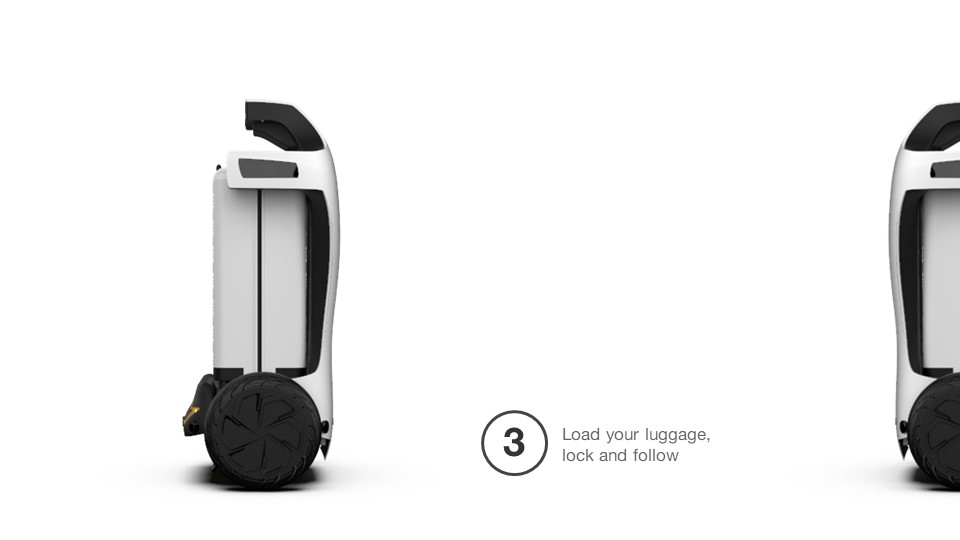
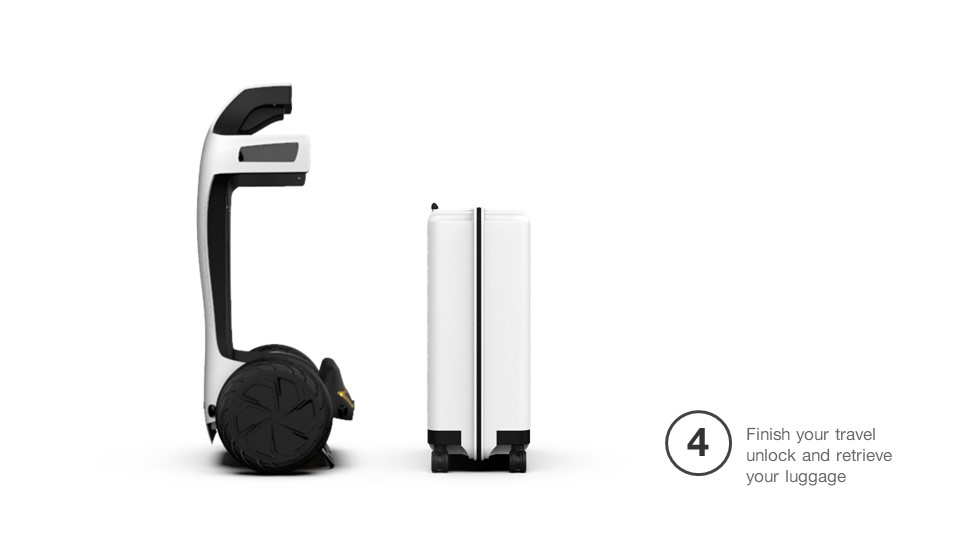
Four phases guide travelers: activate ATA, scan the ticket, load luggage, and choose a mode: Follow, Guide, or Auto-return. Each mode adapts the robot’s behavior to different travel needs.
Technical overview
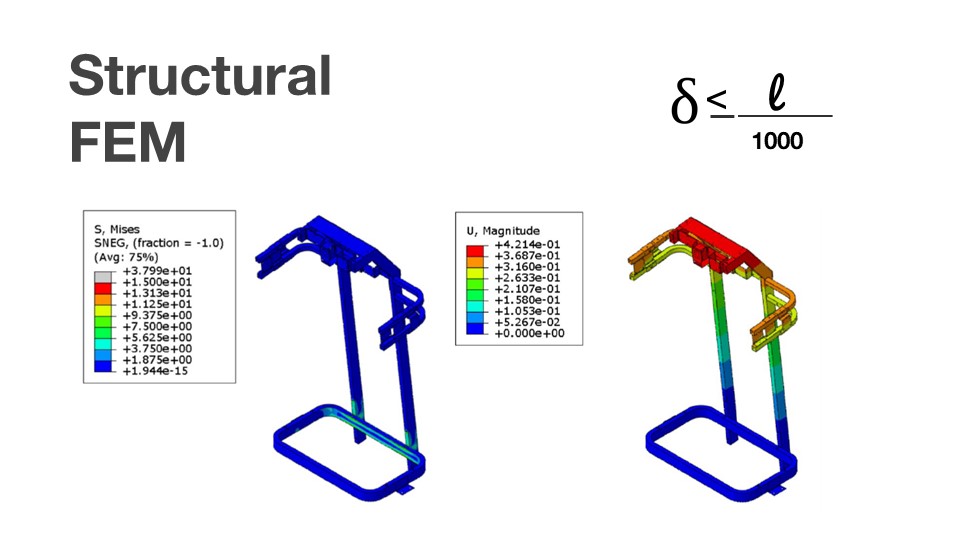
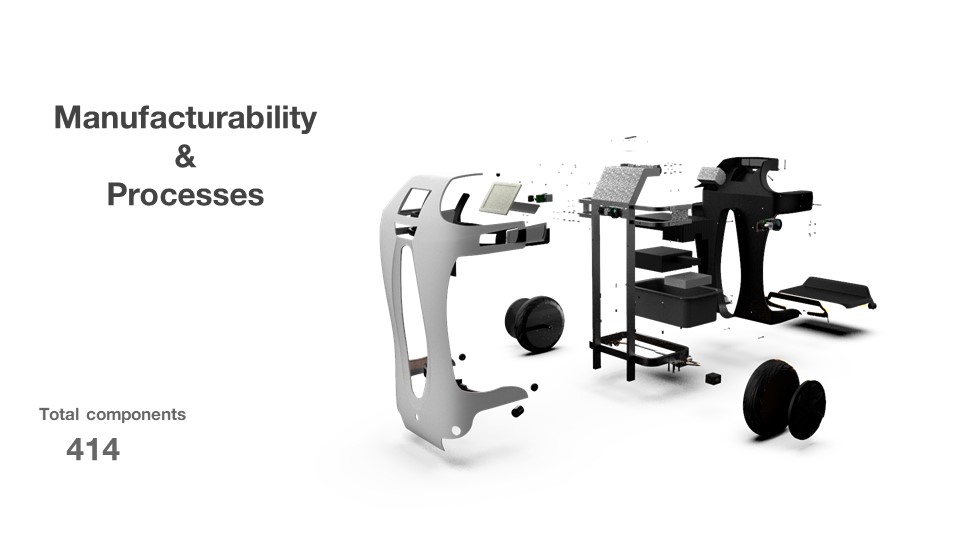
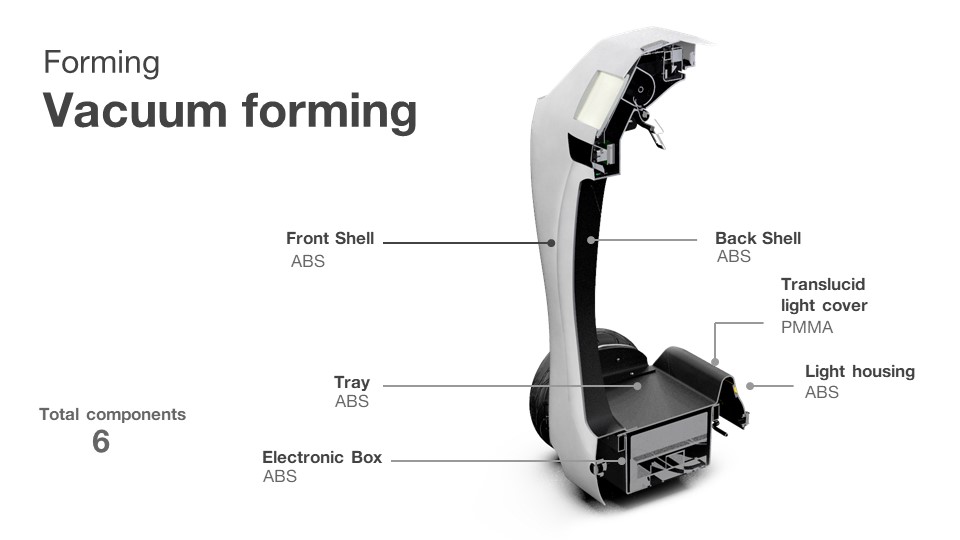
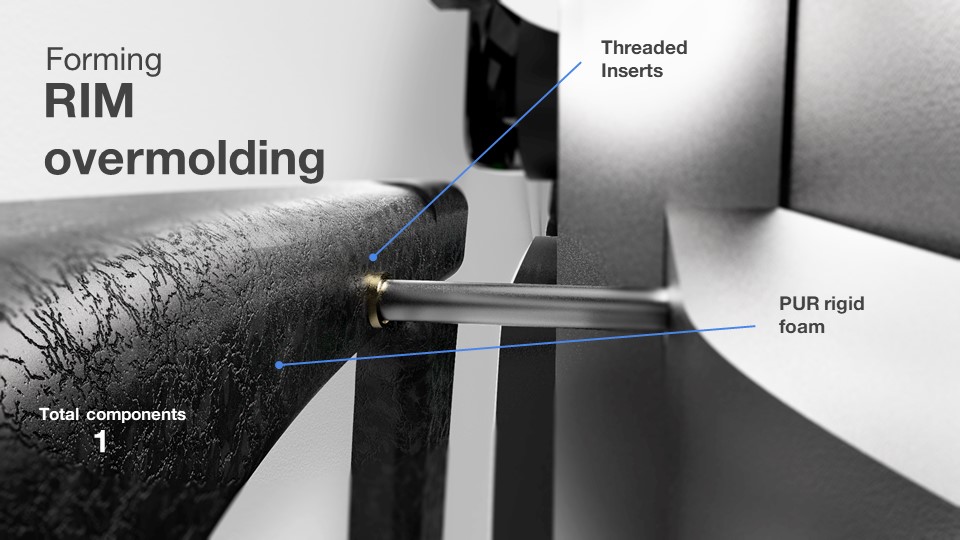
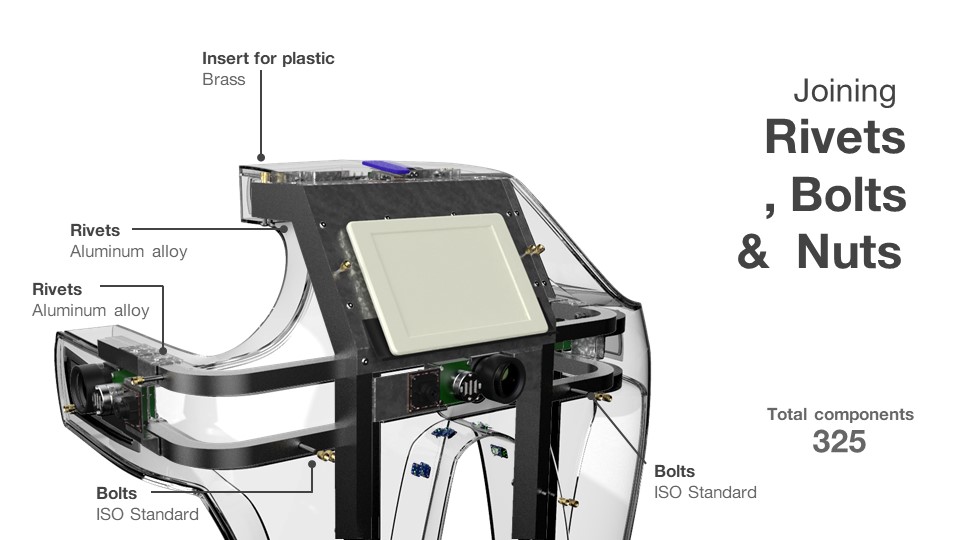
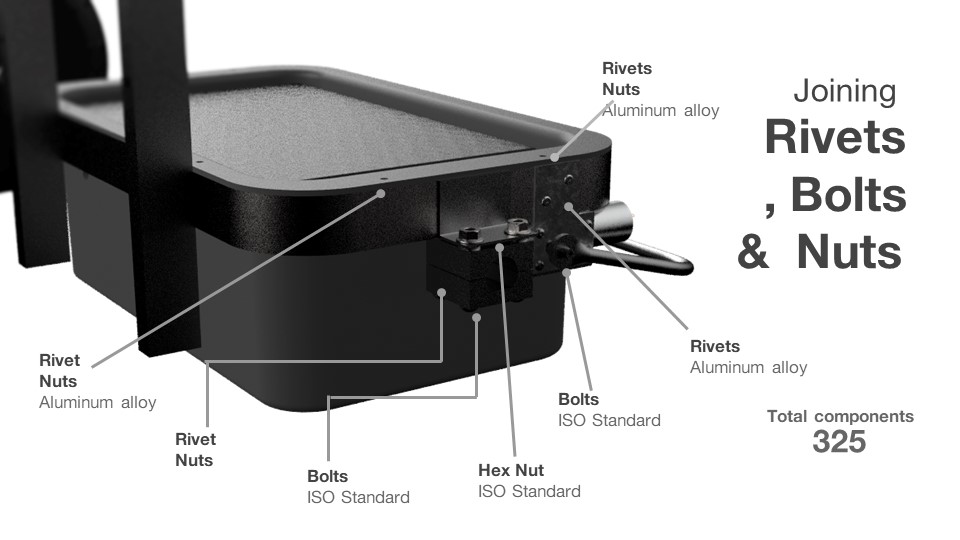
Engineering studies included structural FEA, security system analysis, and design-for-manufacturing optimizations to support 10,000-unit production runs.
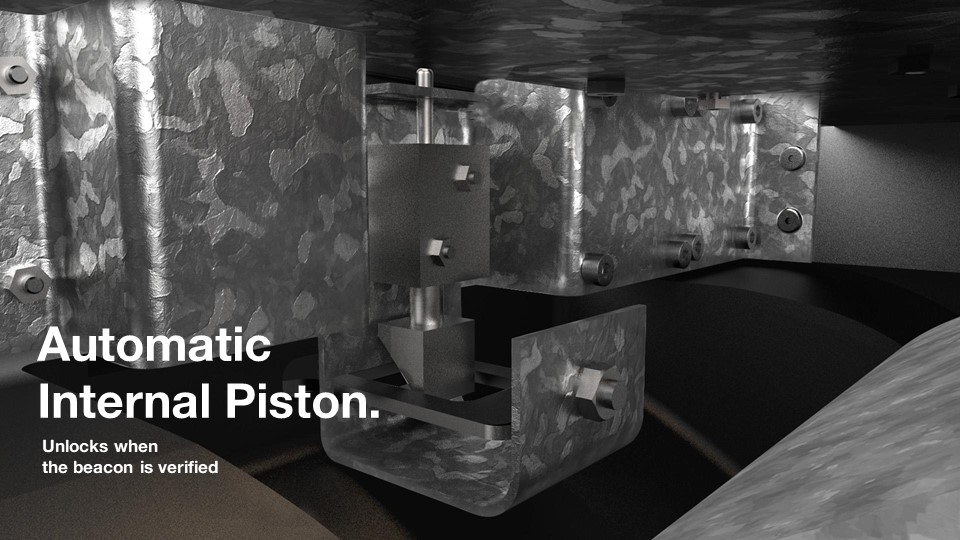
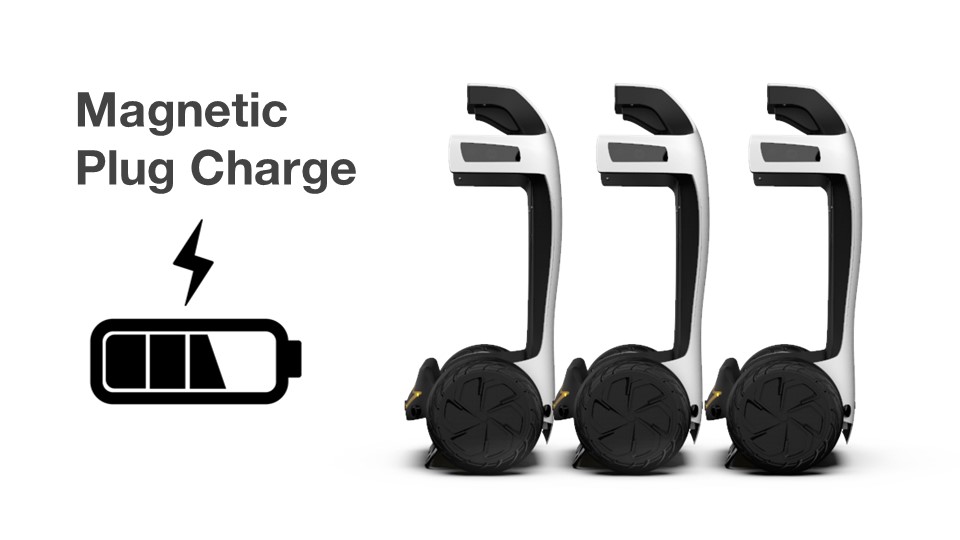
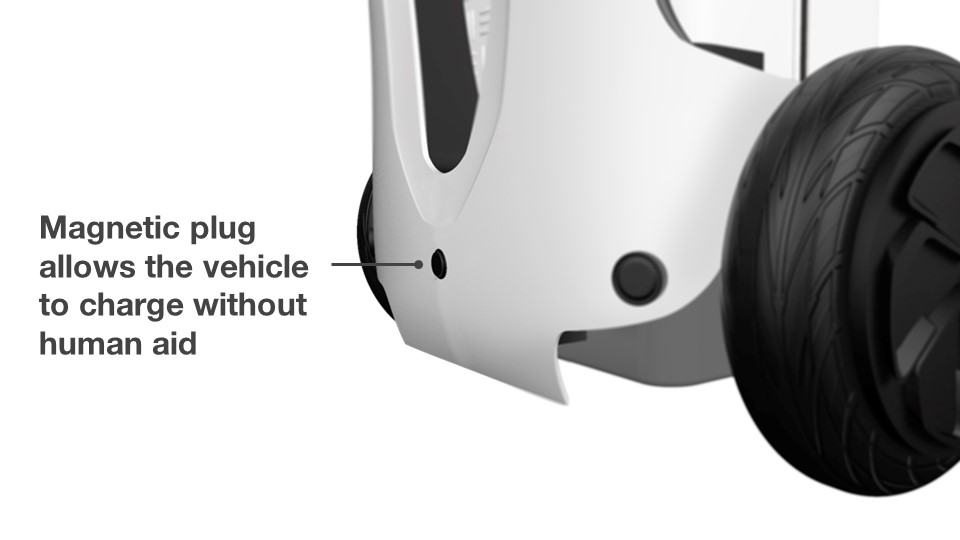
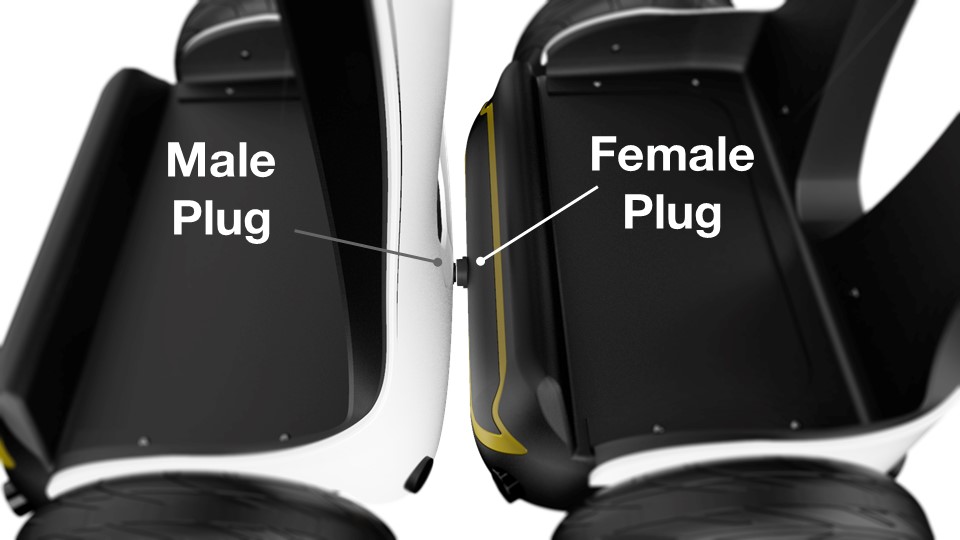
Charging system
Final render